
Hi,
I’m looking to at potentially getting a SES-V2-5DOF and I was wondering if I could get a bit more information before purchasing.
- Is there a good way to estimate the max payload the gripper can hold onto as a function of its arm’s extent? I’m hoping to use the arm to carry items around 250g at a shorter arm extent of 200mm for example and would like to know if this would be feasible.
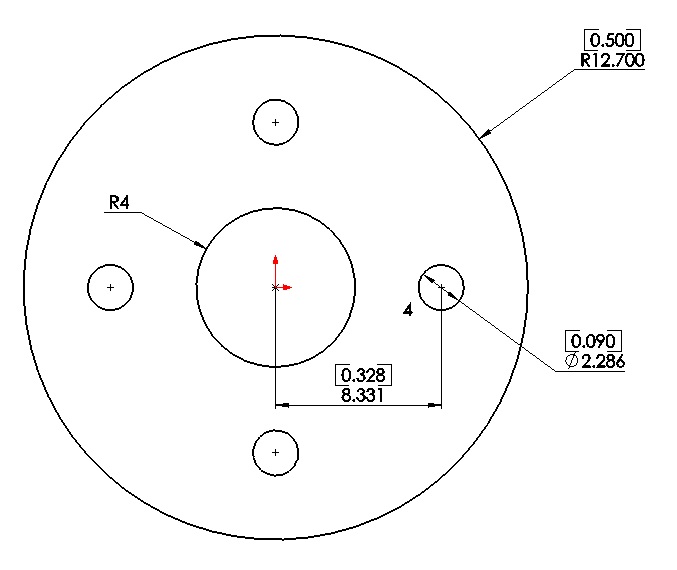
- I was interested in switching out the gripper to a custom finger like effector. Is this relatively straight forward by creating my custom part with the matching screw points to what would hold the gripper?
- I have seen the nice GUI using Flow LSS to control the arm directly from USB. I’m fairly new to using these types of arms, I’m hoping to write up some code to control the arm in Python. Is there a library or API that provides similar functionality to what Flow LSS can do? I want to avoid having to determine the rotation of each servo to hit a specific 3D coordinate.
- From this previous post it mentions that the precision of the device might vary with a heavier load. I was wondering if there is a quantifiable level of inaccuracy for repeated movements when using a 100g load for example.